
Plugin with FANUC CRX Robot
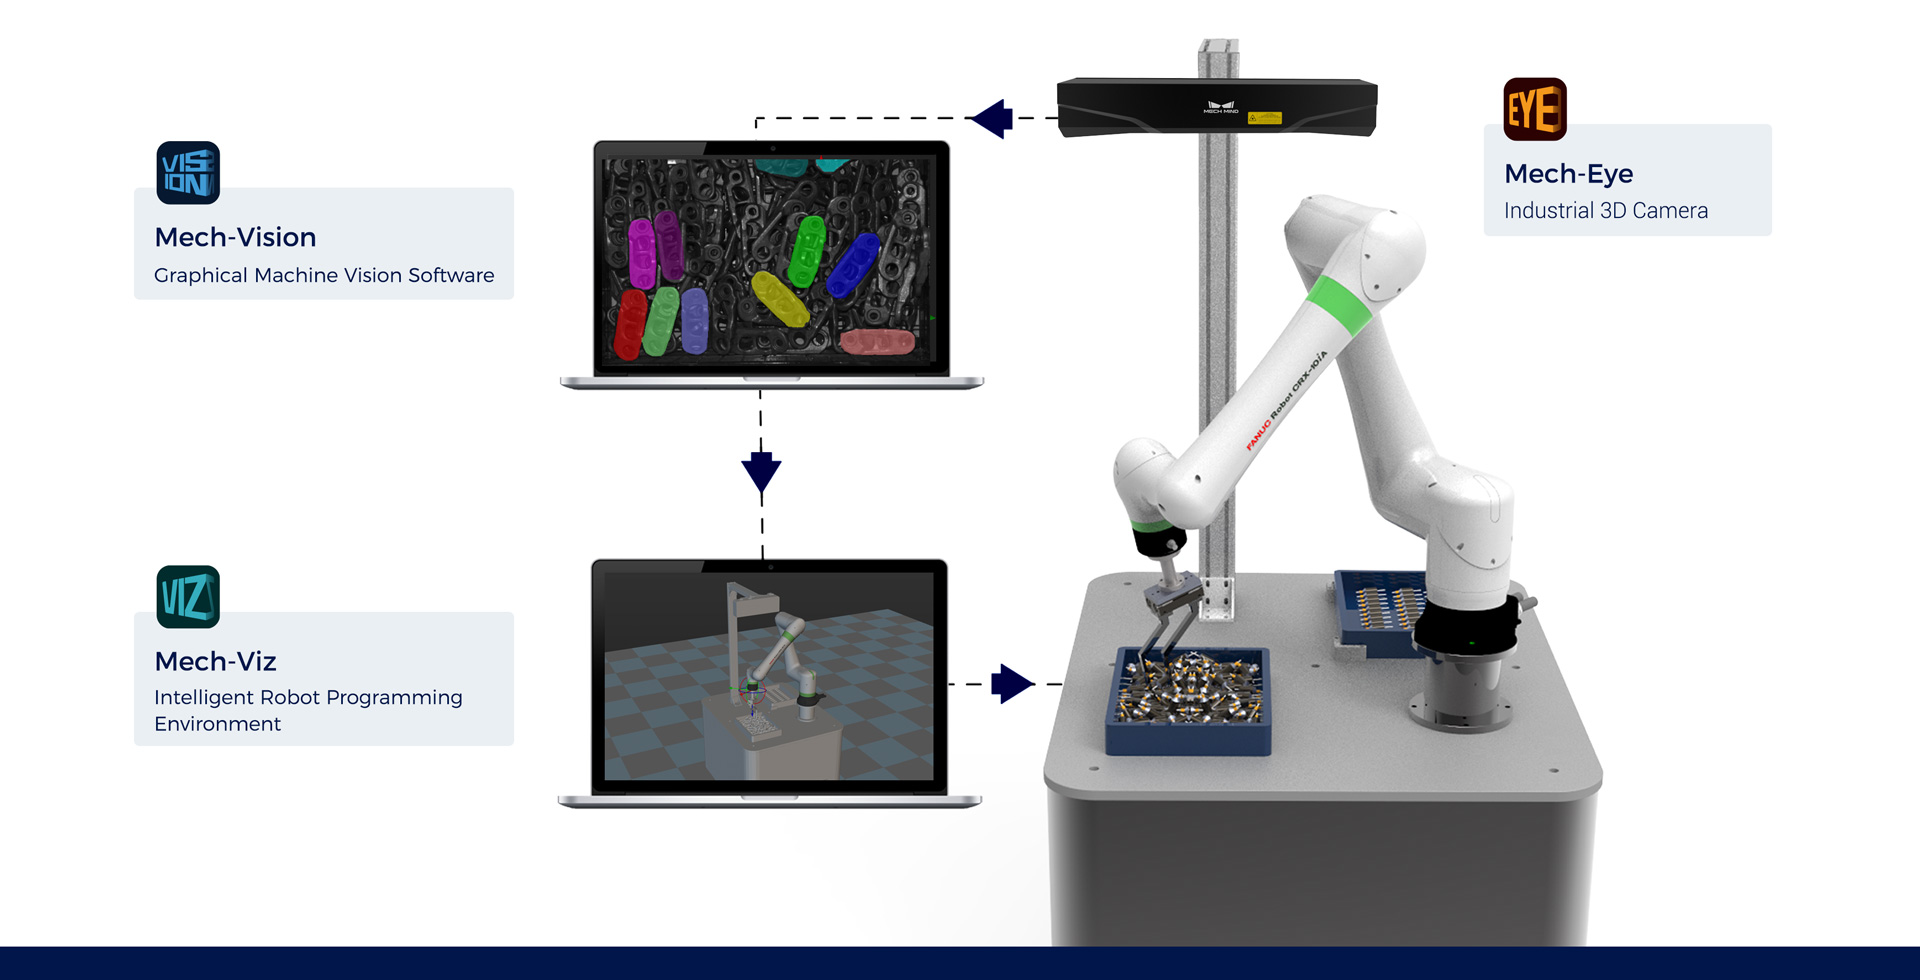
The Typical Workflow
- Capture the object with a 3D camera (Mech-Eye)
- Generate point cloud data of the object (Mech-Eye / Mech-Vision)
- Calculate the position and the gesture of the object (Mech-Vision)
- Control the robot by our software (Mech-Viz)
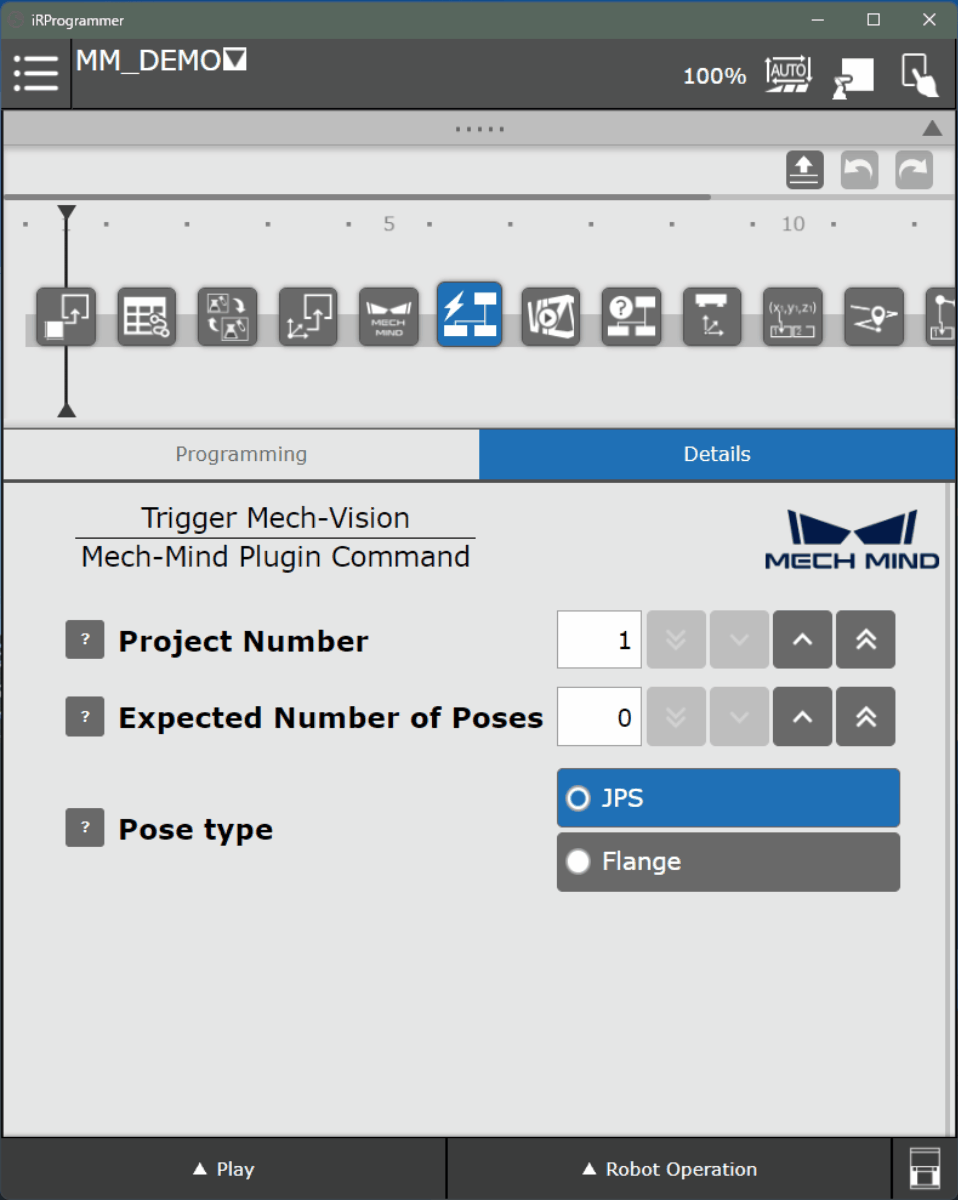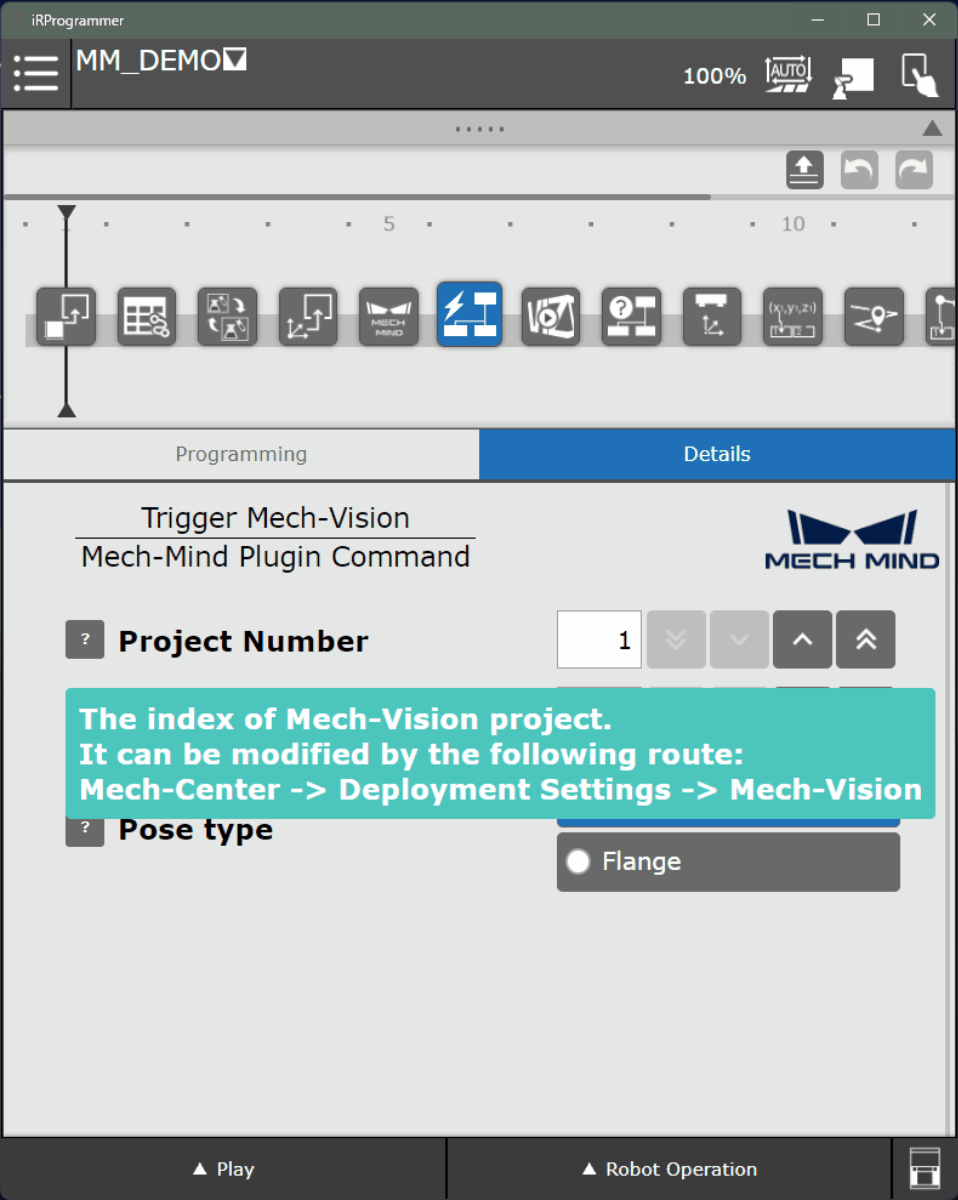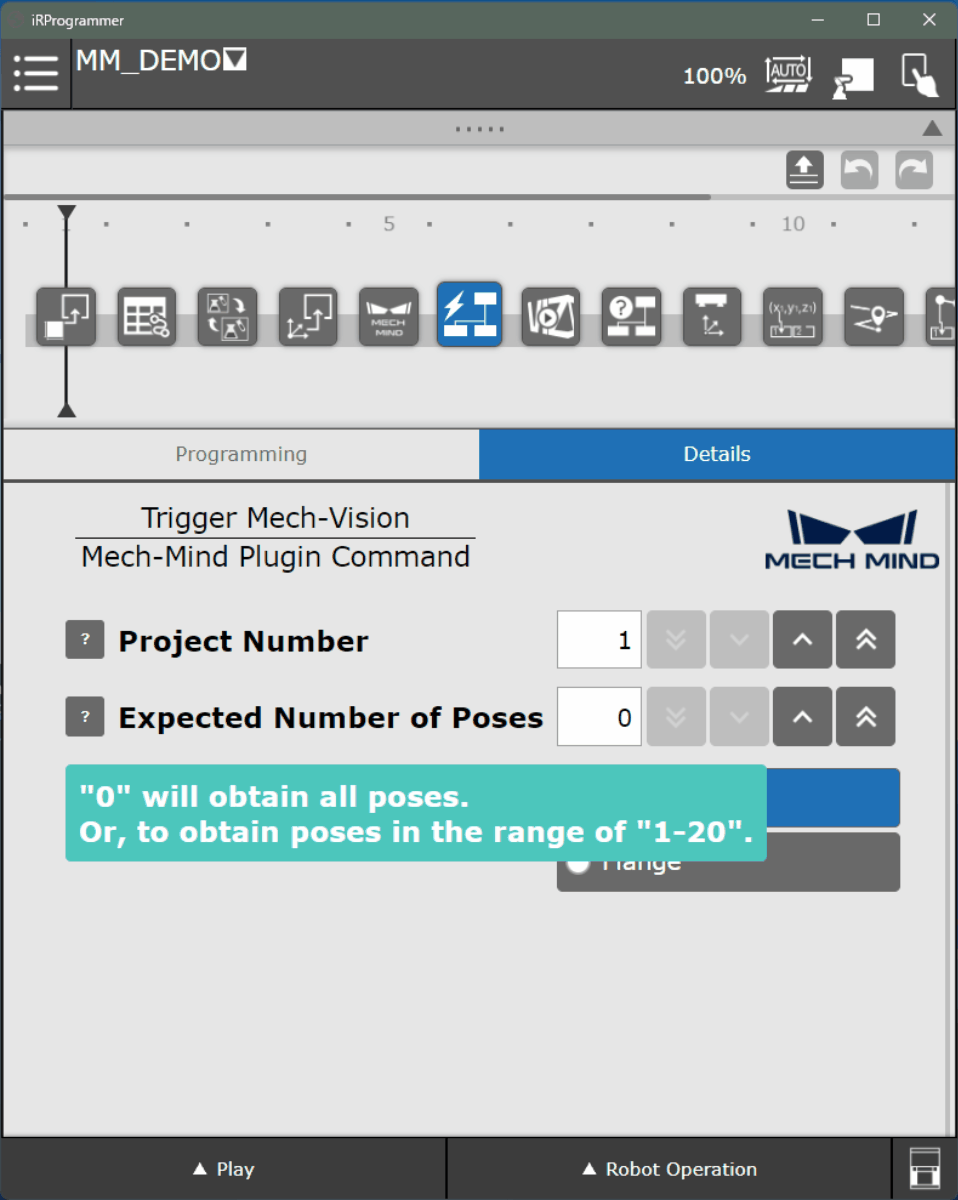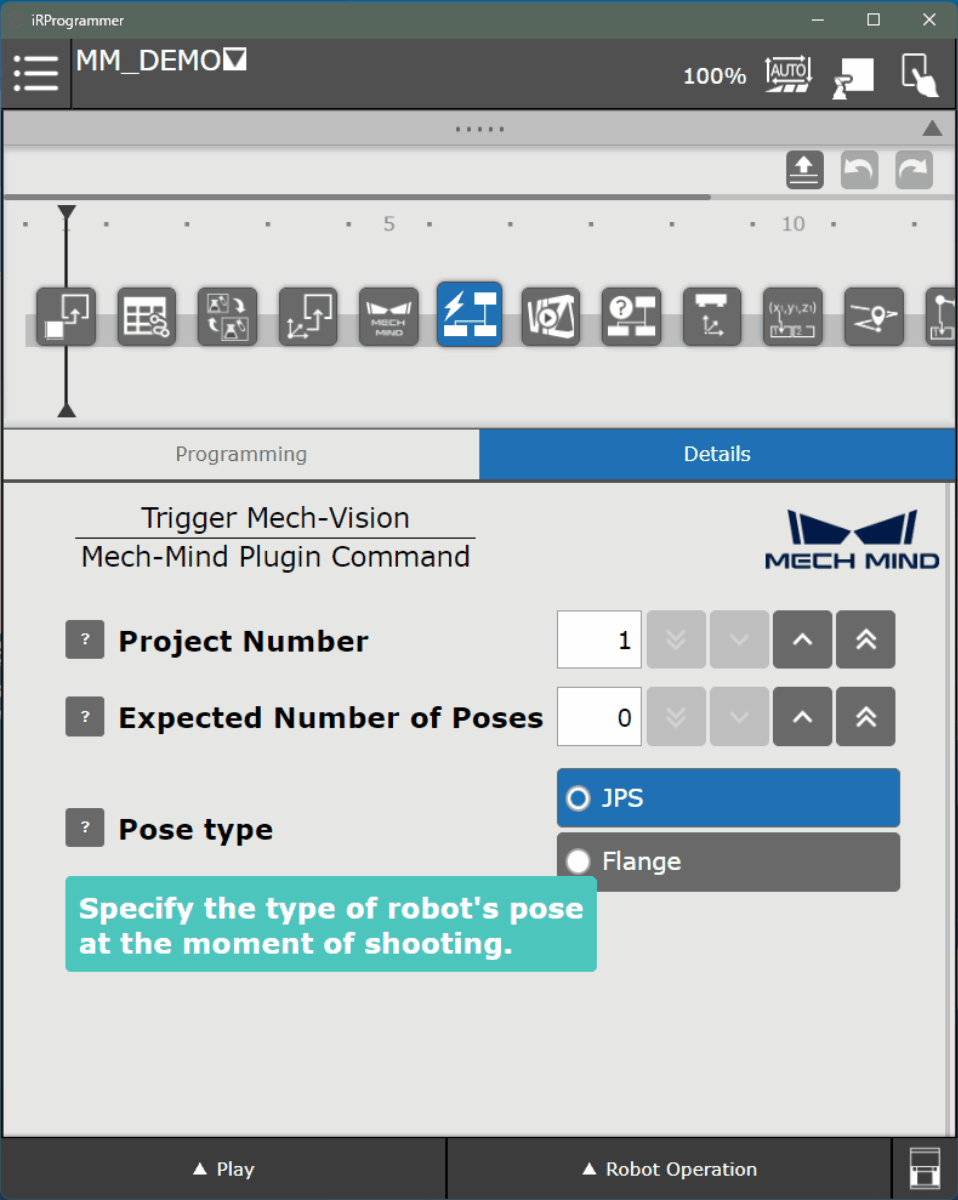
TP Programming Screen
Mech-Mind Commands adapt the new programming style on FANUC-CRX robots.
Simply drag and touch to config TP programming without any complicated input.
Features
The interface is easy to use with the following designs.
- Hint button
- Adapted argument modification
- Documents are available in the plugin menu as attachments
Demonstration Video
First, the TP program triggers our 3D vision system, and sends a request to obtain the pose of the box from our 3D vision system.
Then, move the robot to the picking pose.
Meanwhile, another project is triggered to calculate the placing pose. Finally, the box is placed in the target position and the robot returns to the initial pose.

If you are interested, please feel free to contact us using the inquiry form below
Trusted by Worldwide Leading Companies
